


Wydawcy
Katalog tematyczny
- Archeologia (109)
- Ekonomia, finanse, business (13704)
- Filozofia (1445)
- Historia (3040)
- Języki i językoznawstwo (2356)
- Lifestyle, hobby i rozrywka (475)
- Medycyna (9704)
- Nauki humanistyczne (4)
- Nauki o Ziemi i środowisku (2638)
- Nauki ścisłe (20412)
- Nauki społeczne (8486)
- Nauki techniczne (13450)
- Budownictwo lądowe (1045)
- Chemia przemysłowa (2258)
- Elektronika i telekomunikacja (3287)
- Energetyka (1122)
- Inne nauki stosowane (363)
- Inżynieria biochemiczna (507)
- Inżynieria transportu (232)
- Mechanika i materiały (3316)
- Nauka o środowisku (321)
- Rolnictwo (507)
- Technika, ogólnie (475)
- Prawo (1696)
- Publikacje informacyjne i interdyscyplinarne (1288)
- Religia i wierzenia (917)
- Technika komputerowa (4067)
- Zdrowie, relacje międzyludzkie i rozwój osobisty (657)





Informacje szczegółowe o książce
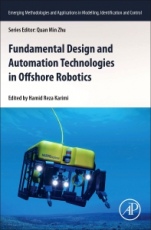
Fundamental Design and Automation Technologies in Offshore Robotics
ISBN 9780128202715
Autor: Karimi, Hamid Reza
Wydawca: Elsevier
Dostępność: 3-6 tygodni
Cena: 817,95 zł
Przed złożeniem zamówienia prosimy o kontakt mailowy celem potwierdzenia ceny.
ISBN13: |
9780128202715 |
Autor: |
Karimi, Hamid Reza |
Oprawa: |
Paperback |
Rok Wydania: |
2020-10-13 |
Tematy: |
TGB |
Fundamental Design and Automation Technologies in Offshore Robotics introduces technological design, modelling, stability analysis, control synthesis, filtering problem and real time operation of robotics vehicles in offshore environments.
The book gives numerical and simulation results in each chapter to reflect the engineering practice yet demonstrate the focus of the developed analysis and synthesis approaches. The book is ideal to be used as a reference book for senior and graduate students. It is written in a way that the presentation is simple, clear, and easy to read and understand which would be appreciated by graduate students. Researchers working on marine vehicles and robotics would be able to find reference material on related topics from the book.
The book could be of a significant interest to the researchers within offshore and deep see society, including both academic and industrial parts.
Provides a series of latest results in, including but not limited to, motion control, robotics, and multi-vehicle systems towards offshore environmentPresents recent advances of theory, technological aspects, and applications of robotics in offshore environmentOffers a comprehensive and up-to-date references, which plays an indicative role for further study of the reader
1. Introduction to fundamental design and automation
technologies in offshore robotics
2. Continuous system integration and validation for underwater
perception in offshore inspection and intervention tasks
3. Azimuth thruster single lever type remote control system
4. Autonomous environment and target perception of underwater
offshore vehicles
5. Autonomous control of underwater offshore vehicles
6. Development of hybrid control architecture for a small
autonomous underwater vehicle
7. Adaptive sliding mode control based on local recurrent neural
networks for an underwater robot
8. Thruster fault reconstruction for autonomous underwater vehicle
based on terminal sliding mode observer
9. Robust sampled-data control for dynamic positioning ships
based on T–S fuzzymodel
10. Finite-time control of autonomous surface vehicles
11. Way-point tracking control of underactuated USV based on GPC
path planning
12. ESO-based guidance law for distributed path maneuvering
of multiple autonomous surface vehicles with a time-varying
formation
13. Finite-time extended state observer based fault tolerant output
feedback control for UAV attitude stabilization under actuator
failures and disturbances
Koszyk
Książek w koszyku: 0 szt.
Wartość zakupów: 0,00 zł
Informacje


Kontakt
Gambit
Centrum Oprogramowania
i Szkoleń Sp. z o.o.
Al. Pokoju 29b/22-24
31-564 Kraków
Siedziba Księgarni
ul. Kordylewskiego 1
31-542 Kraków
+48 12 410 5991
+48 12 410 5987
+48 12 410 5989
Subskrypcje
Administratorem danych osobowych jest firma Gambit COiS Sp. z o.o. Na podany adres będzie wysyłany wyłącznie biuletyn informacyjny.
Autoryzacja płatności

Informacje na temat autoryzacji płatności poprzez PayU.
© Copyright 2012: GAMBIT COiS Sp. z o.o. Wszelkie prawa zastrzeżone.
Projekt i wykonanie: Alchemia Studio Reklamy